2012:Robot Design Details: Difference between revisions
From 1511Wookiee
Jump to navigationJump to search
No edit summary |
|||
| (6 intermediate revisions by 2 users not shown) | |||
| Line 1: | Line 1: | ||
== Current Design == | |||
*Pictures of robot: | |||
**[http://penfieldrobotics.com/wiki/images/2/29/FR_Robot-Back.pdf Robot Back] | |||
**[http://penfieldrobotics.com/wiki/images/b/bb/FR_Robot-Conveyors.pdf Robot Conveyors] | |||
**[http://penfieldrobotics.com/wiki/images/c/cc/FR_Robot-Front.pdf Robot Front] | |||
**[http://penfieldrobotics.com/wiki/images/2/2b/FR_Robot-Iso.pdf Robot Iso] | |||
**[http://penfieldrobotics.com/wiki/images/4/45/FR_Robot-Left.pdf Robot Left] | |||
**[http://penfieldrobotics.com/wiki/images/2/2e/FR_Robot-Right.pdf Robot Right] | |||
**[http://penfieldrobotics.com/wiki/images/b/b4/FR_Robot-Top.pdf Robot Top] | |||
**[http://penfieldrobotics.com/wiki/images/f/f7/FR_Robot-Turret.pdf Robot Turret] | |||
== Preliminary Design == | == Preliminary Design == | ||
| Line 27: | Line 40: | ||
-Need to shoot over 60ft. | -Need to shoot over 60ft. | ||
== Robot Specifications == | == Robot Specifications == | ||
Overall: | |||
'''Overall:''' | |||
*Time from collection to shooting should be less than 2 seconds. | |||
*The direction that the balls leave the robot must be opposite from the side of the robot that collects the balls. | |||
Shooter: | *All designs need to be robust so that time spent fixing the robot is to a minimum. | ||
*All parts should be easily serviced if needed. | |||
'''Shooter:''' | |||
*Must be consistent within 2 degrees of the hoop when shooting from the key. | |||
Storage: | *Range must be from at least the barrier of the far zone to the basket. | ||
*Must be able to shoot over 60 inch obstacles. | |||
*Desired to have a design conducive to a automated aiming system. | |||
*Time between command to fire and ball firing must be less than 0.5 seconds. | |||
Collector: | '''Storage:''' | ||
*Must have ability to queue balls to get them ready to fire as soon as possible. | |||
*Must have sensors to detect ball movement through the system. | |||
Bridge Articulator: | *Must be able to remove balls from the system when the robot is turned off. | ||
*Speed of transit must satisfy combined collection to shoot time of 2 seconds. | |||
'''Collector:''' | |||
Drivetrain: | *Must be able to be turned off and on quickly. | ||
*Must be able to pick up balls that are located on the wall of the court easily. | |||
*Must be able to pick up a ball when in contact with the collector and immediately (<0.2 seconds) pass it to the storage system. | |||
'''Bridge Articulator:''' | |||
*Must be able to exert enough force to lower the bridge to the point where the drive train can easily get on the bridge. | |||
*Needs to be able to take the abuse of another robot or force resisting the motion of putting down the bridge. | |||
*Must be able to manipulate the bridge from horizontal to drive over position in less than 1 second. | |||
*It would also be useful to have the articulator assist in ball collection. | |||
'''Drivetrain:''' | |||
*Must be able to easily transverse the barrier and bridges in less than 2 seconds. | |||
*Max Drivetrain speed should be between 10 to 11ft/s. | |||
*Drivetrain must have slow mode for fine control on bridges and barriers. | |||
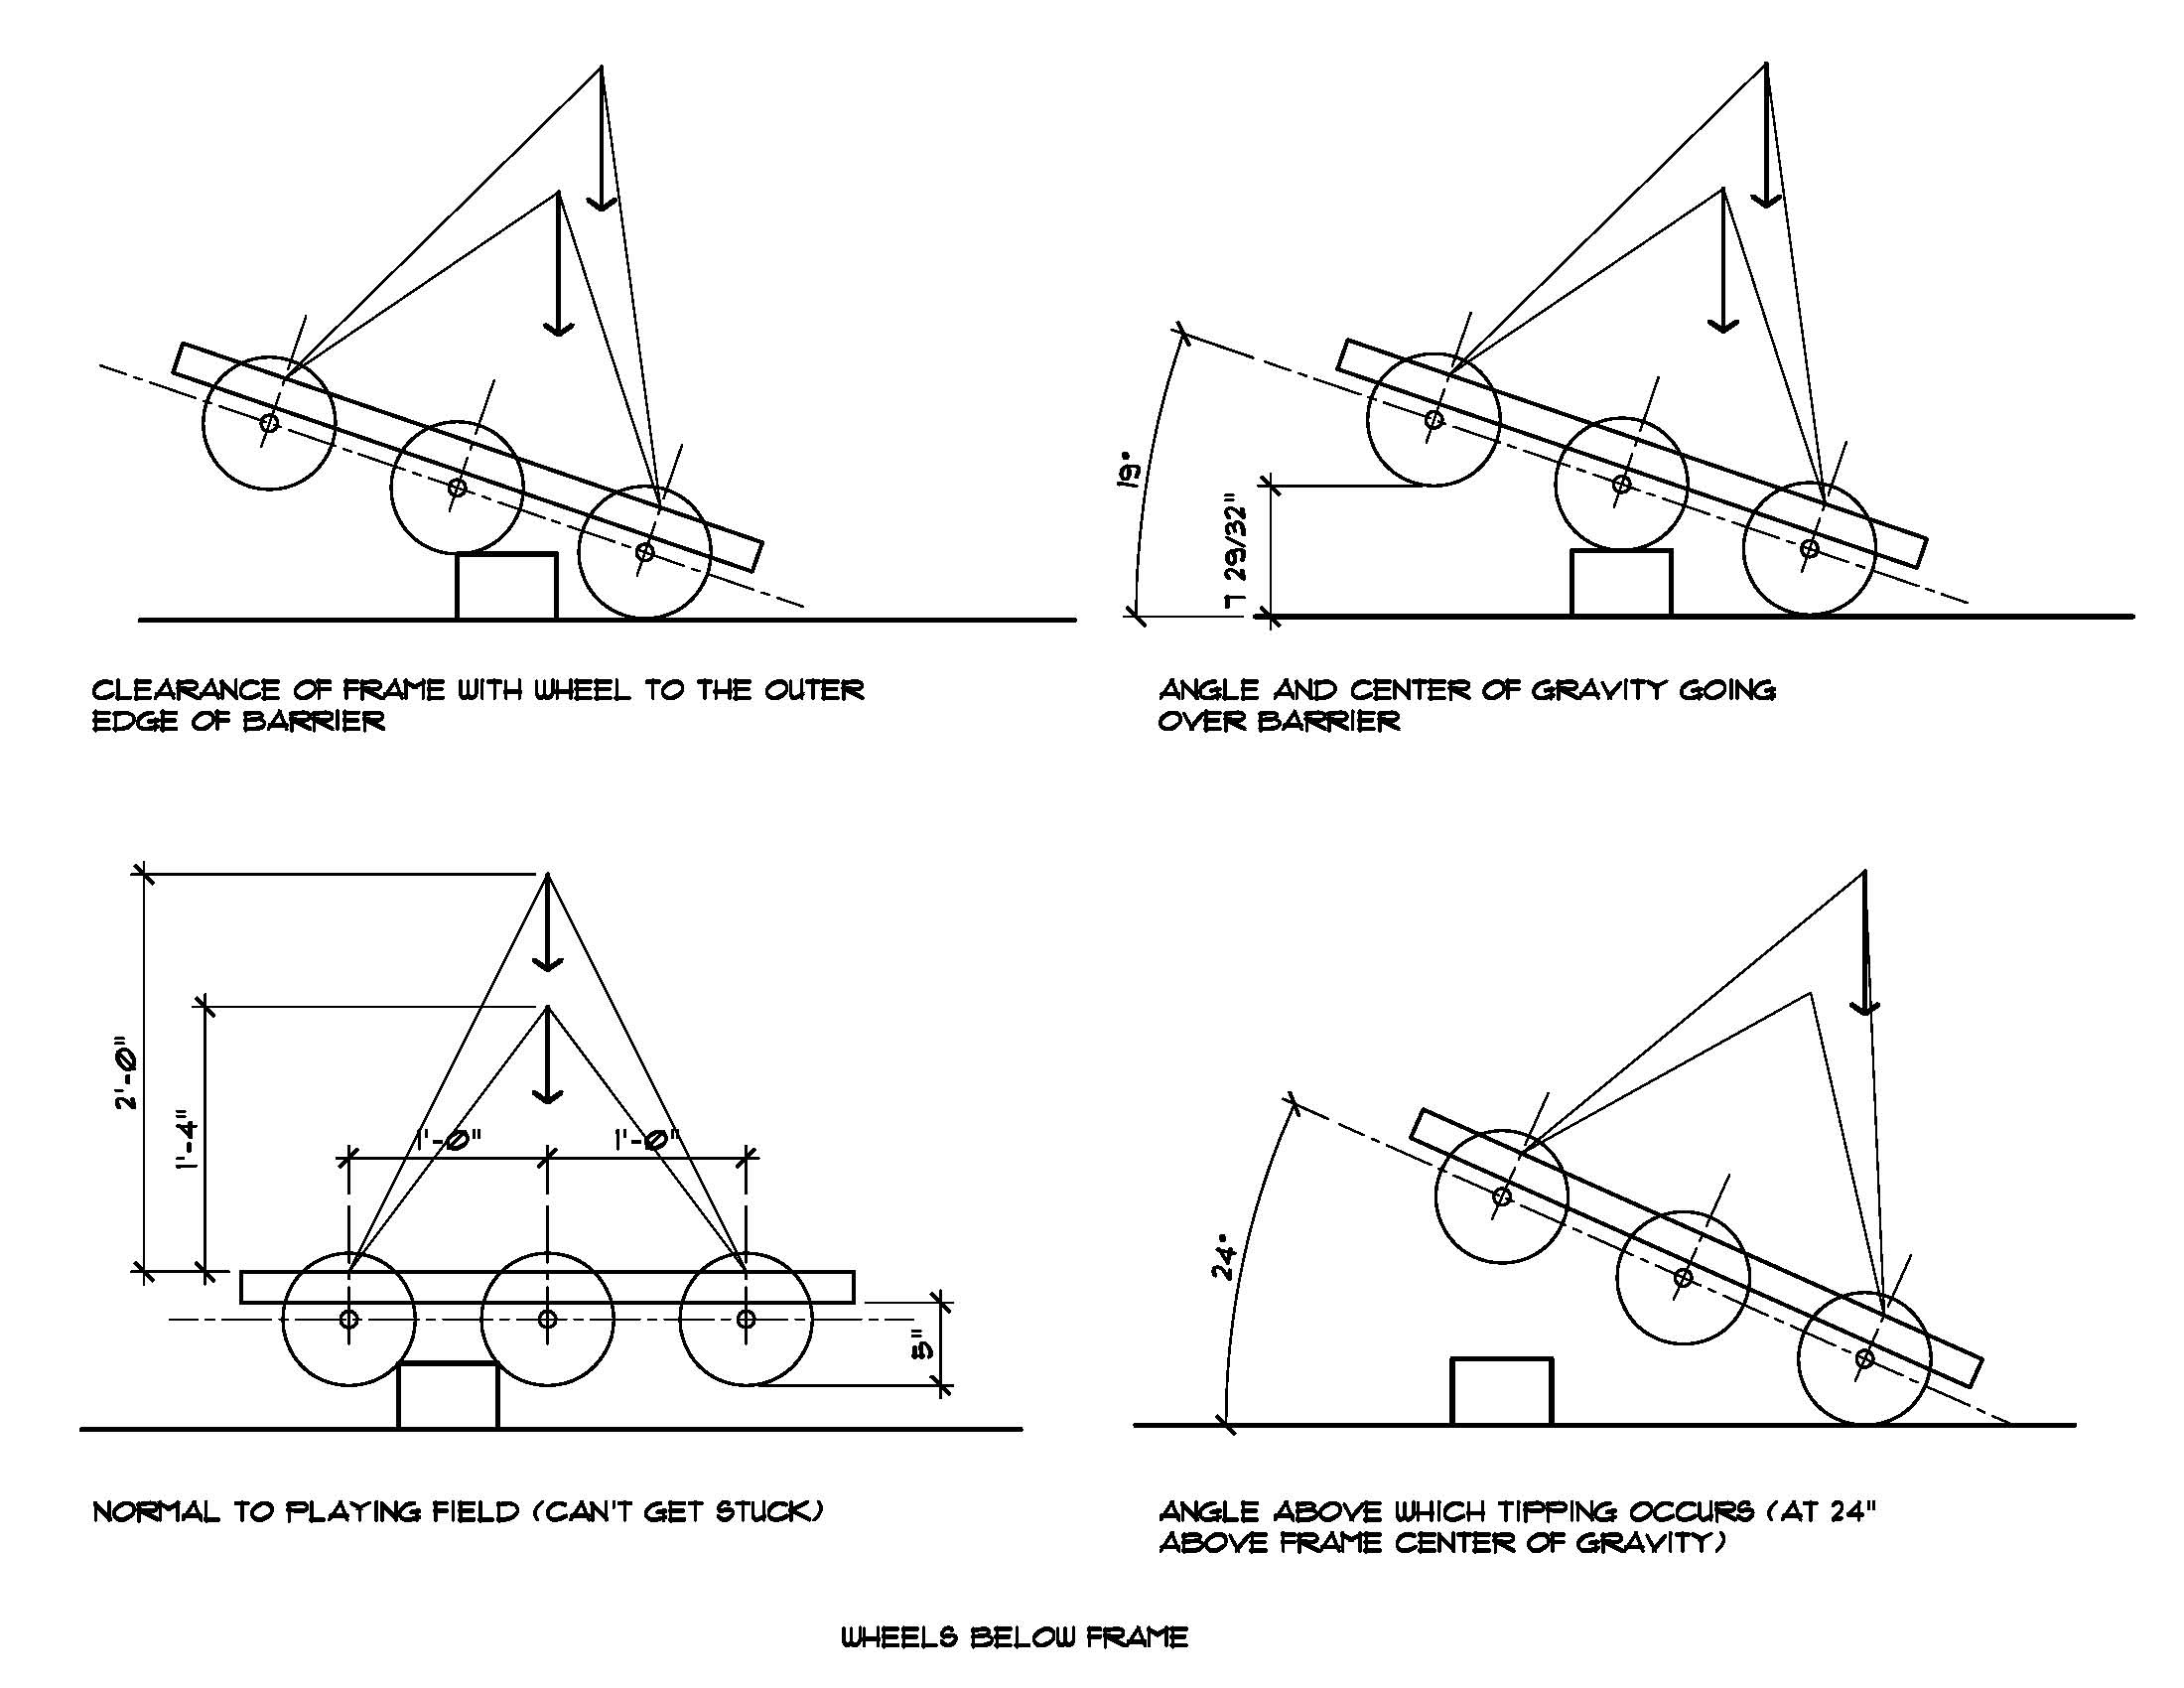
*Sketches for frame height/wheel base can be found [[Media:ForeDiagramWheelsAligned.jpg|here ]]and [[Media:WheelsBelowFrame.jpg|here]]. | |||
== Main Robot Design == | == Main Robot Design == | ||
Latest revision as of 21:39, 7 February 2012
Current Design
- Pictures of robot:
Preliminary Design
Preliminary design after Sunday January 8th Design Sessions
-Drivetrain - 6 Wheel Pnuematic
-Collectors to prototype
-Stationary Beater Bar
-Actuator Beater Bar and Wings
-Hungry Hungry Hippos
-U Shaped Brush
-Bridge Actuators to prototype
-Actuator also acts as collector
-actuator is seperate from collector
-Storage will be 3 stage
-Shooter will be a turret
-Spinning wheels to shoot
-Need backspin on ball
-Variable Speed
-Variable angle (could be speed)
-Need to shoot over 60ft.
Robot Specifications
Overall:
- Time from collection to shooting should be less than 2 seconds.
- The direction that the balls leave the robot must be opposite from the side of the robot that collects the balls.
- All designs need to be robust so that time spent fixing the robot is to a minimum.
- All parts should be easily serviced if needed.
Shooter:
- Must be consistent within 2 degrees of the hoop when shooting from the key.
- Range must be from at least the barrier of the far zone to the basket.
- Must be able to shoot over 60 inch obstacles.
- Desired to have a design conducive to a automated aiming system.
- Time between command to fire and ball firing must be less than 0.5 seconds.
Storage:
- Must have ability to queue balls to get them ready to fire as soon as possible.
- Must have sensors to detect ball movement through the system.
- Must be able to remove balls from the system when the robot is turned off.
- Speed of transit must satisfy combined collection to shoot time of 2 seconds.
Collector:
- Must be able to be turned off and on quickly.
- Must be able to pick up balls that are located on the wall of the court easily.
- Must be able to pick up a ball when in contact with the collector and immediately (<0.2 seconds) pass it to the storage system.
Bridge Articulator:
- Must be able to exert enough force to lower the bridge to the point where the drive train can easily get on the bridge.
- Needs to be able to take the abuse of another robot or force resisting the motion of putting down the bridge.
- Must be able to manipulate the bridge from horizontal to drive over position in less than 1 second.
- It would also be useful to have the articulator assist in ball collection.
Drivetrain:
- Must be able to easily transverse the barrier and bridges in less than 2 seconds.
- Max Drivetrain speed should be between 10 to 11ft/s.
- Drivetrain must have slow mode for fine control on bridges and barriers.
- Sketches for frame height/wheel base can be found here and here.